Isaac ROS DNN Inference
NVIDIA-accelerated DNN model inference ROS 2 packages using NVIDIA Triton/TensorRT for both Jetson and x86_64 with CUDA-capable GPU.
Webinar Available
Learn how to use this package by watching our on-demand webinar: Accelerate YOLOv5 and Custom AI Models in ROS with NVIDIA Isaac
Overview
Isaac ROS DNN Inference contains ROS 2 packages for performing DNN inference, providing AI-based perception for robotics applications. DNN inference uses a pre-trained DNN model to ingest an input Tensor and output a prediction to an output Tensor.
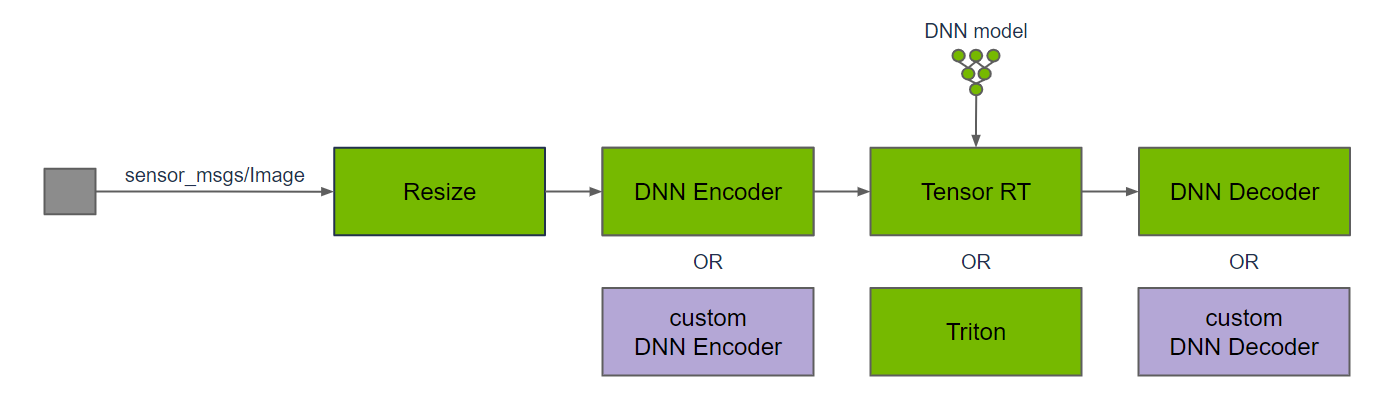
Above is a typical graph of nodes for DNN inference on image data. The input image is resized to match the input resolution of the DNN; the image resolution may be reduced to improve DNN inference performance, which typically scales directly with the number of pixels in the image. DNN inference requires input Tensors, so a DNN encoder node is used to convert from an input image to Tensors, including any data pre-processing that is required for the DNN model. Once DNN inference is performed, the DNN decoder node is used to convert the output Tensors to results that can be used by the application.
TensorRT and Triton are two separate ROS nodes to perform DNN inference. The TensorRT node uses TensorRT to provide high-performance deep learning inference. TensorRT optimizes the DNN model for inference on the target hardware, including Jetson and discrete GPUs. It also supports specific operations that are commonly used by DNN models. For newer or bespoke DNN models, TensorRT may not support inference on the model. For these models, use the Triton node.
The Triton node uses the Triton Inference Server, which provides a compatible frontend supporting a combination of different inference backends (e.g. ONNX Runtime, TensorRT Engine Plan, TensorFlow, PyTorch). In-house benchmark results measure little difference between using TensorRT directly or configuring Triton to use TensorRT as a backend.
Some DNN models may require custom DNN encoders to convert the input data to the Tensor format needed for the model, and custom DNN decoders to convert from output Tensors into results that can be used in the application. Leverage the DNN encoder and DNN decoder nodes for image bounding box detection and image segmentation, or your own custom nodes.
[!Note] DNN inference can be performed on different types of input data, including audio, video, text, and various sensor data, such as LIDAR, camera, and RADAR. This package provides implementations for DNN encode and DNN decode functions for images, which are commonly used for perception in robotics. The DNNs operate on Tensors for their input, output, and internal transformations, so the input image needs to be converted to a Tensor for DNN inferencing.
ROS 2 Native rosidl::Buffer Acceleration
This package uses rosidl::Buffer, a feature built into ROS 2 Lyrical, to avoid unnecessary copies of large payloads between CPU and accelerator memory. The CUDA buffer backend builds on this native ROS 2 feature to provide CUDA memory storage and transport. Most applications can use standard ROS messages and conversion packages without depending directly on a buffer backend. See rosidl::Buffer and Buffer Backends for details.
Performance
| Sample Graph |
Input Size |
AGX Thor T5000 |
AGX Thor T4000 |
AGX Orin |
Orin Nano Super 8GB |
DGX Spark |
x86_64 w/ RTX 5090 |
x86_64 w/ RTX 5070 |
|---|---|---|---|---|---|---|---|---|
| TensorRT Node DOPE |
VGA |
194 fps 1.4 ms @ 30Hz |
128 fps 1.4 ms @ 30Hz |
47.4 fps 1.7 ms @ 30Hz |
20.8 fps |
108 fps 1.5 ms @ 30Hz |
350 fps 0.51 ms @ 30Hz |
162 fps 0.58 ms @ 30Hz |
| Triton Node DOPE |
VGA |
176 fps 5.8 ms @ 30Hz |
117 fps 8.7 ms @ 30Hz |
45.0 fps 23 ms @ 30Hz |
20.2 fps |
97.5 fps 9.8 ms @ 30Hz |
347 fps 2.9 ms @ 30Hz |
156 fps 6.4 ms @ 30Hz |
| TensorRT Node PeopleSemSegNet |
544p |
821 fps 0.98 ms @ 30Hz |
530 fps 1.0 ms @ 30Hz |
484 fps 1.5 ms @ 30Hz |
235 fps 2.0 ms @ 30Hz |
978 fps 1.0 ms @ 30Hz |
– |
2310 fps 0.53 ms @ 30Hz |
| Triton Node PeopleSemSegNet |
544p |
193 fps 6.1 ms @ 30Hz |
187 fps 5.6 ms @ 30Hz |
191 fps 5.6 ms @ 30Hz |
123 fps 8.7 ms @ 30Hz |
176 fps 5.7 ms @ 30Hz |
– |
1640 fps 0.70 ms @ 30Hz |
| DNN Image Encoder Node |
1200p |
1190 fps 2.6 ms @ 30Hz |
1030 fps 2.6 ms @ 30Hz |
820 fps 2.0 ms @ 30Hz |
563 fps 2.4 ms @ 30Hz |
909 fps 1.6 ms @ 30Hz |
– |
– |
Documentation
Please visit the Isaac ROS Documentation to learn how to use this repository.
Packages
Latest
Update 2026-11-16: Restored the PyTorch backend in Triton source builds on x86_64 and aarch64